Skills Practice
Electronics
H-Bridges
Protoshields
Arduino IDE
Project Syopsis
IR REMOTE CONTROLLED CAR
I came up with 4 projects that use an Arduino Uno protoshield. The main project in this video was something I started that was worth moving from a breadboard and onto a protoshield; an IR Remote Controlled Car Using a Protoshield. When I thought about which shield to use, I knew I wanted something like the official Arduino Uno shield that came without the headers pre soldered, but something like the Elegoo Uno protoshield that had more useful traces. I share which protoshields I chose, the parts I used, the code, layout and schematics.
Components, Boards and Software


Building the IR Remote Controlled Car
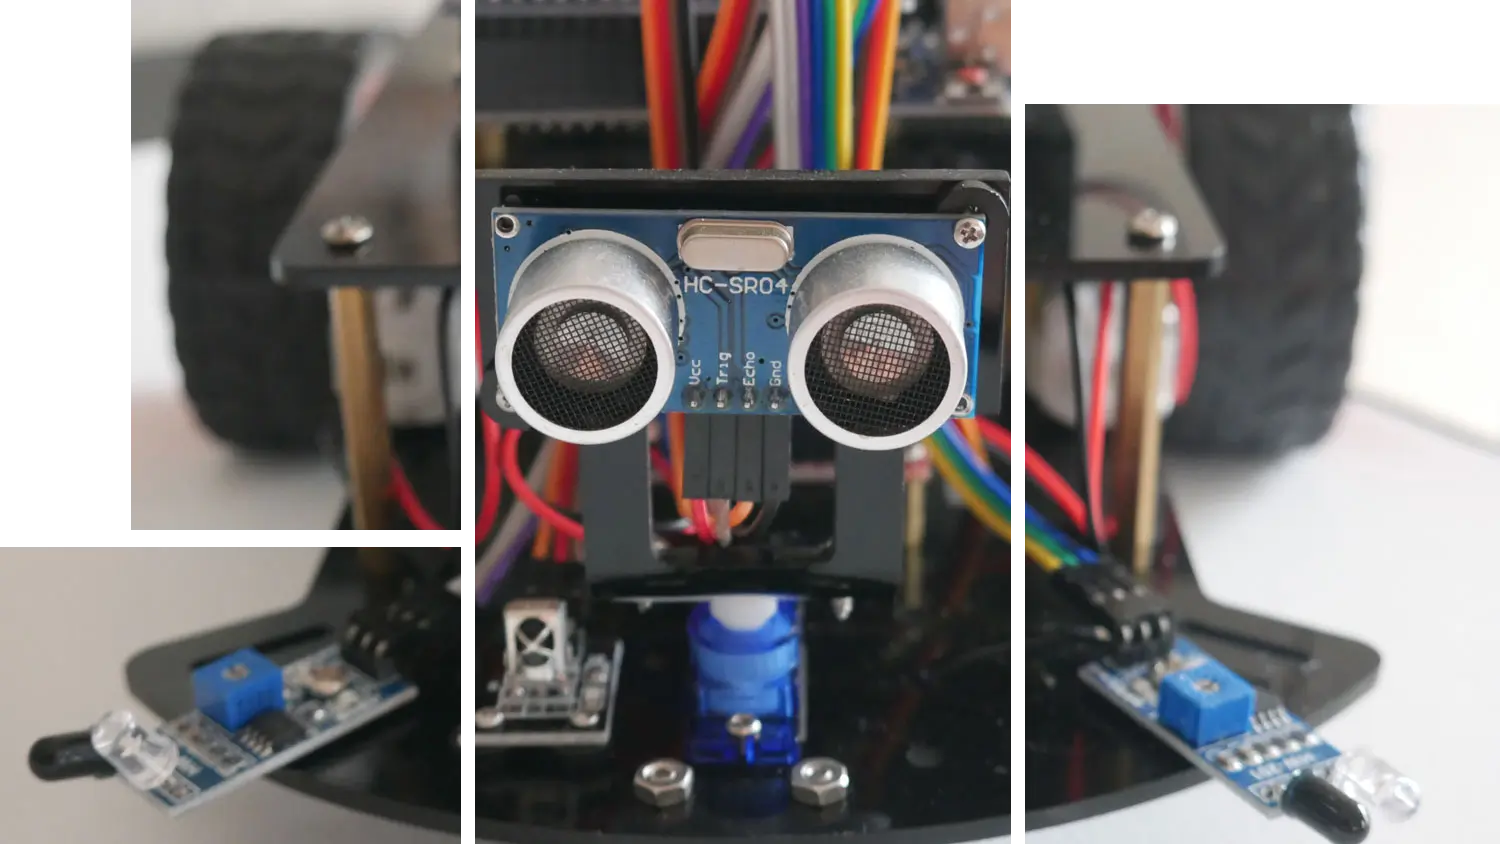
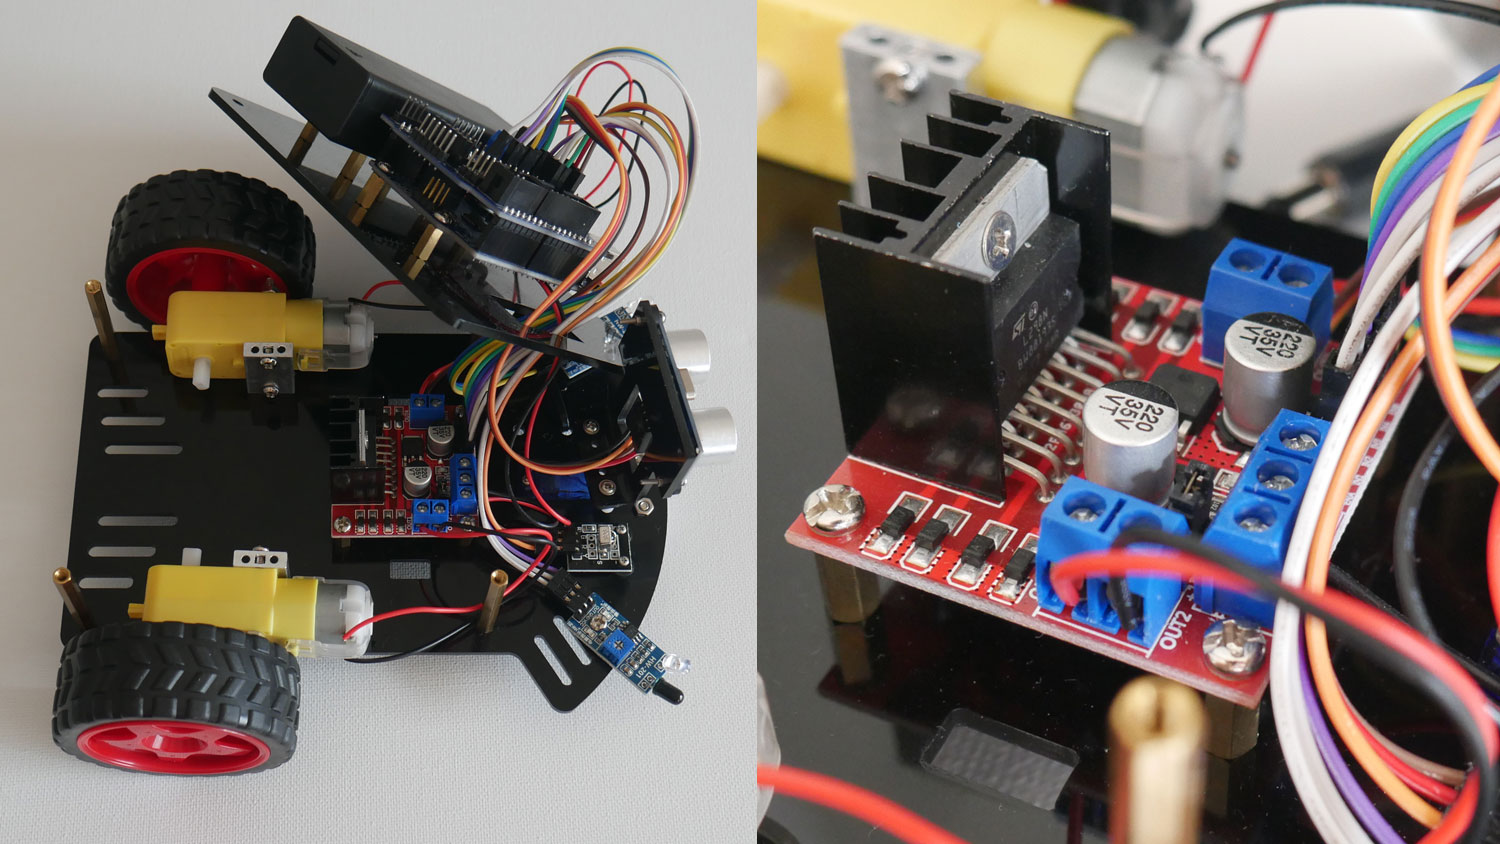
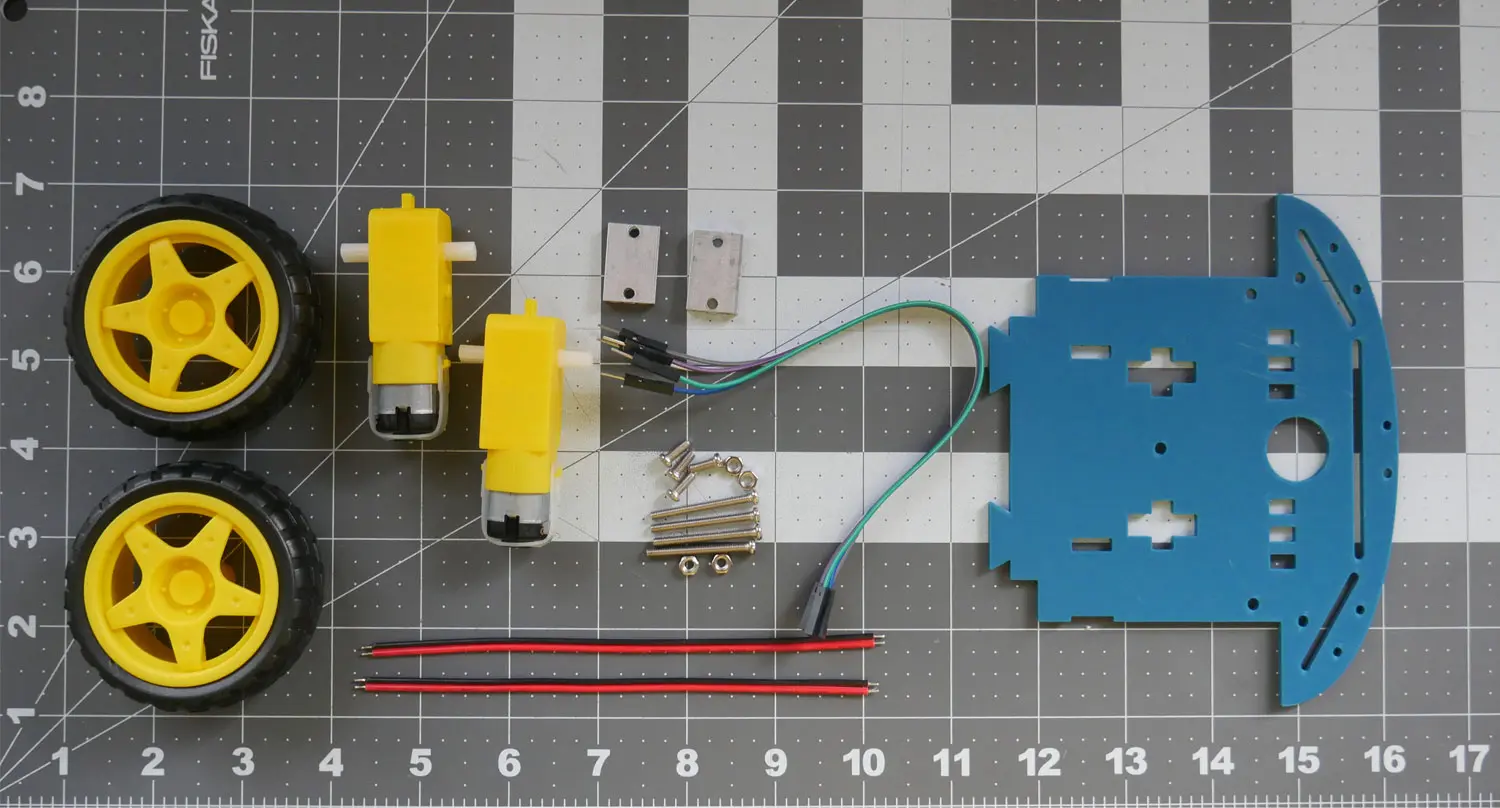
Before I started this project I also purchased a smart car kit.
This is the Hosyound Kit. It was very easy to assemble and I thought the car was too big so, I was disappointed with the experience.
However, to be fair, I think the point of those kits is to introduce us to its basic concepts and components and that leads to next steps. So, my next step was to make a slightly smaller version of this smart car. I thought that this l298N H-bridge motor driver was way too big.
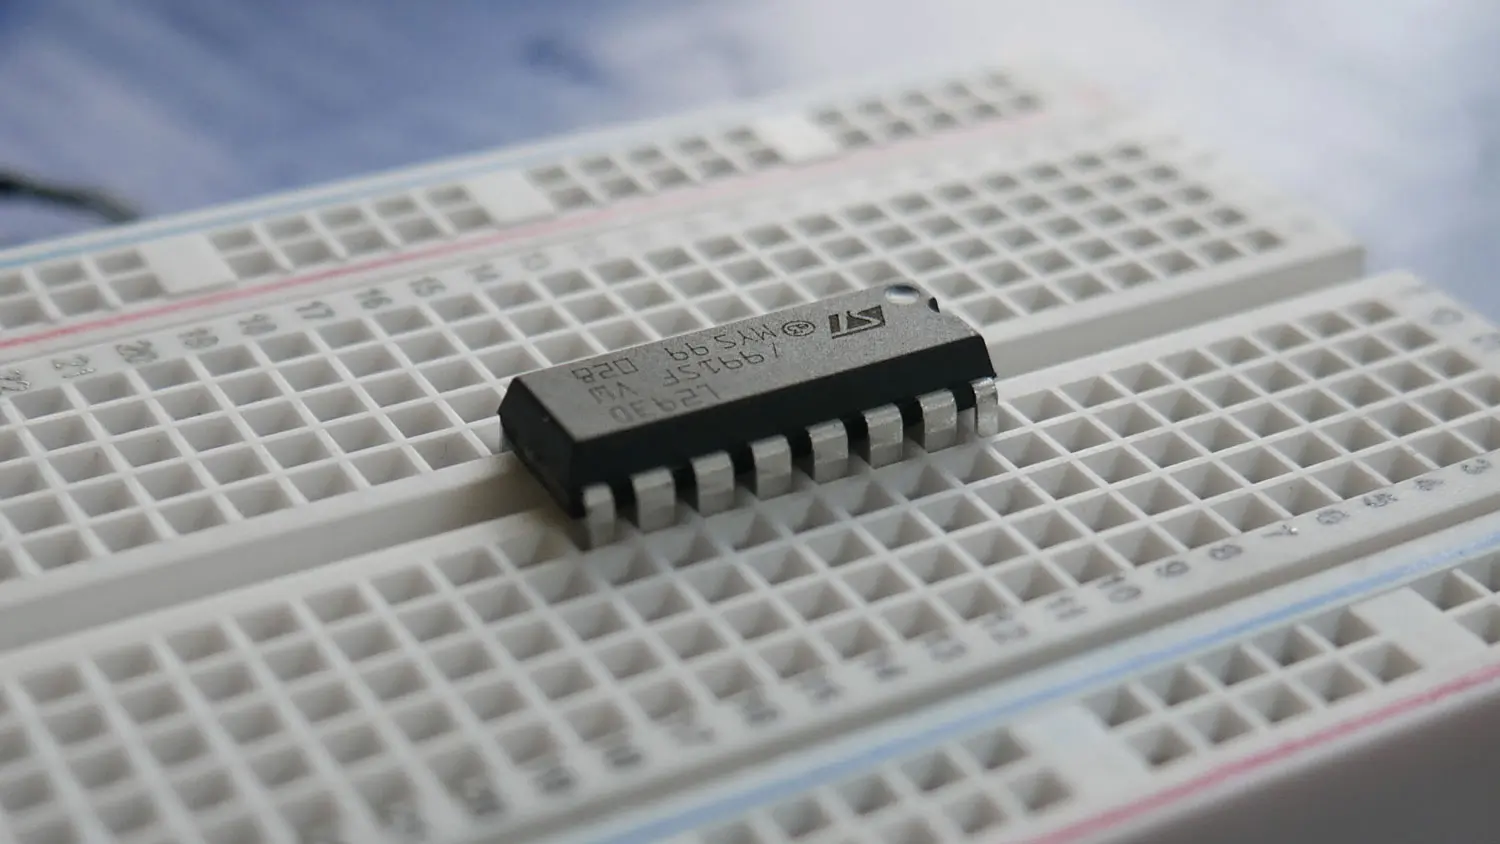
I replaced the L298N with an L293D H-bridge motor driver.
Using a smaller H-bridge was when I realized that a protoshield was a big part of how I would simplify this project.
THE PROTOSHIELD
I thought about which protoshield to use? My Elegoo shield wasn’t going work for this because the female header pins were already soldered onto the board. My official Arduino Shield wasn’t an option because it cost R114 and I wasn’t willing to waste it on this project. I wanted something like the official Uno protoshield that came without the headers pre soldered but was laid out like the Elegoo Uno protoshield and was also inexpensive. I looked online and found these and they looked promising.
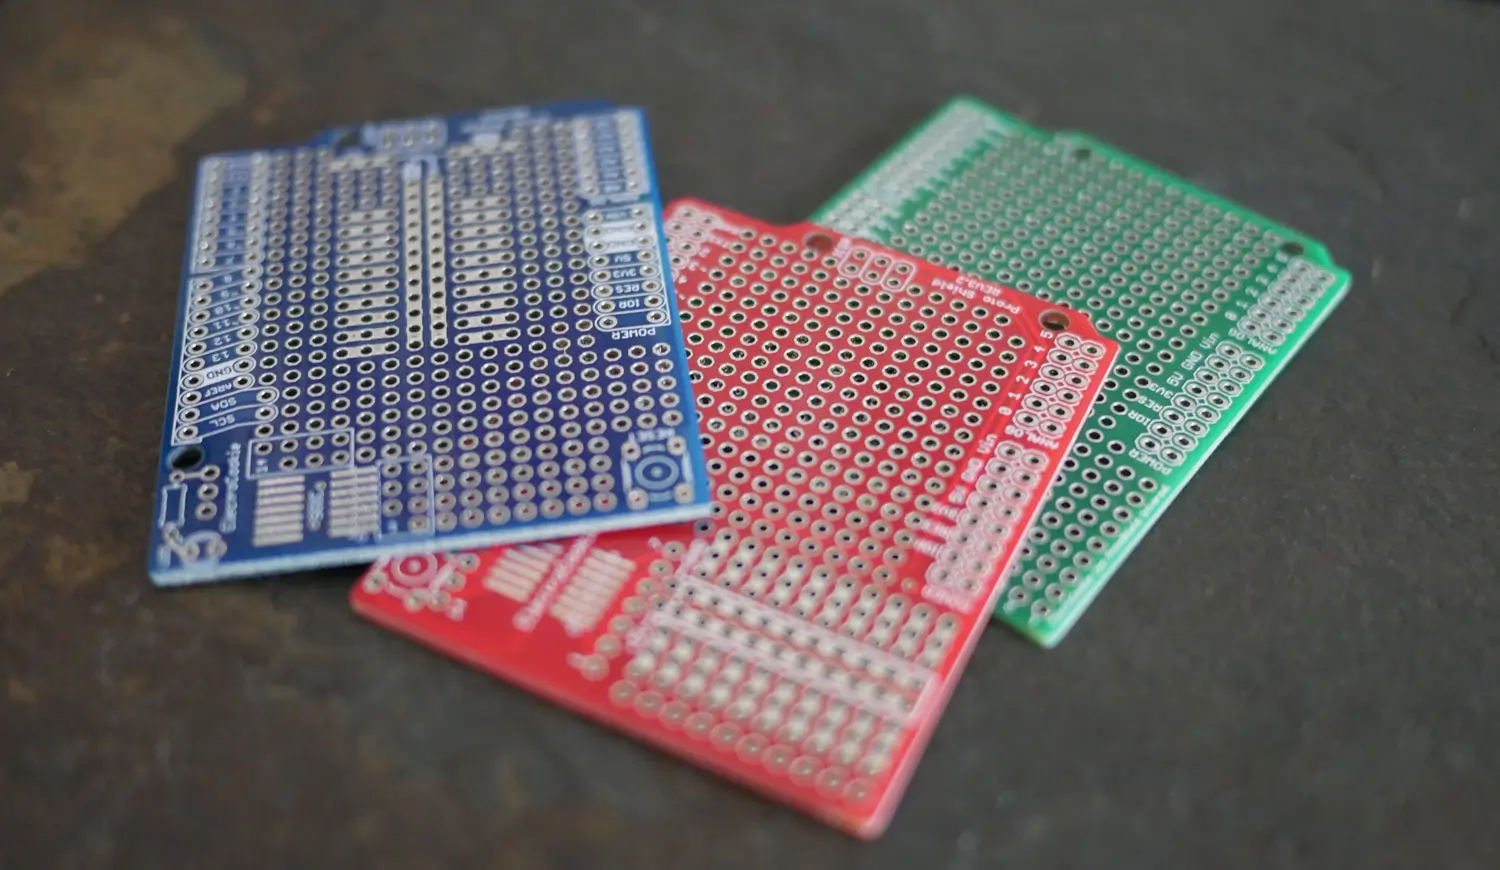
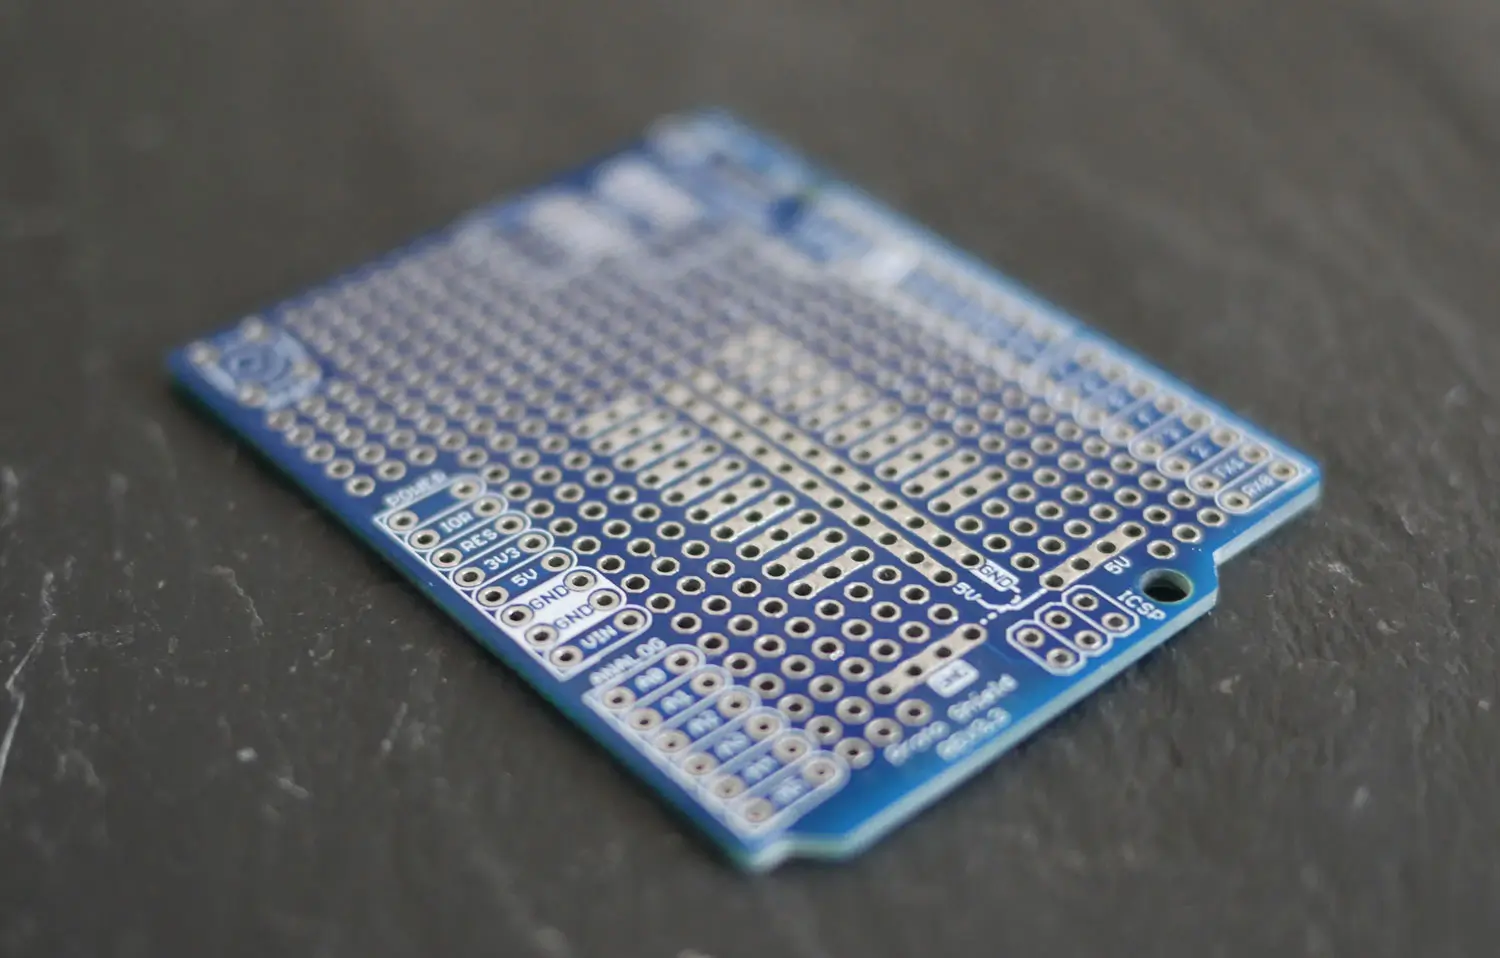
This blue shield came as part of a pack of 9 Arduino Uno protoshields by ElectroCookie.
The Electrocookie pack came without the header pins pre-soldered and provided three different layouts. The biggest attraction was the price; R115.00 That's around R11.50 per shield! Now I was ready to create my first protoshield.
ORIGINAL PROJECT: CAR THAT FOLLOWS LIGHT
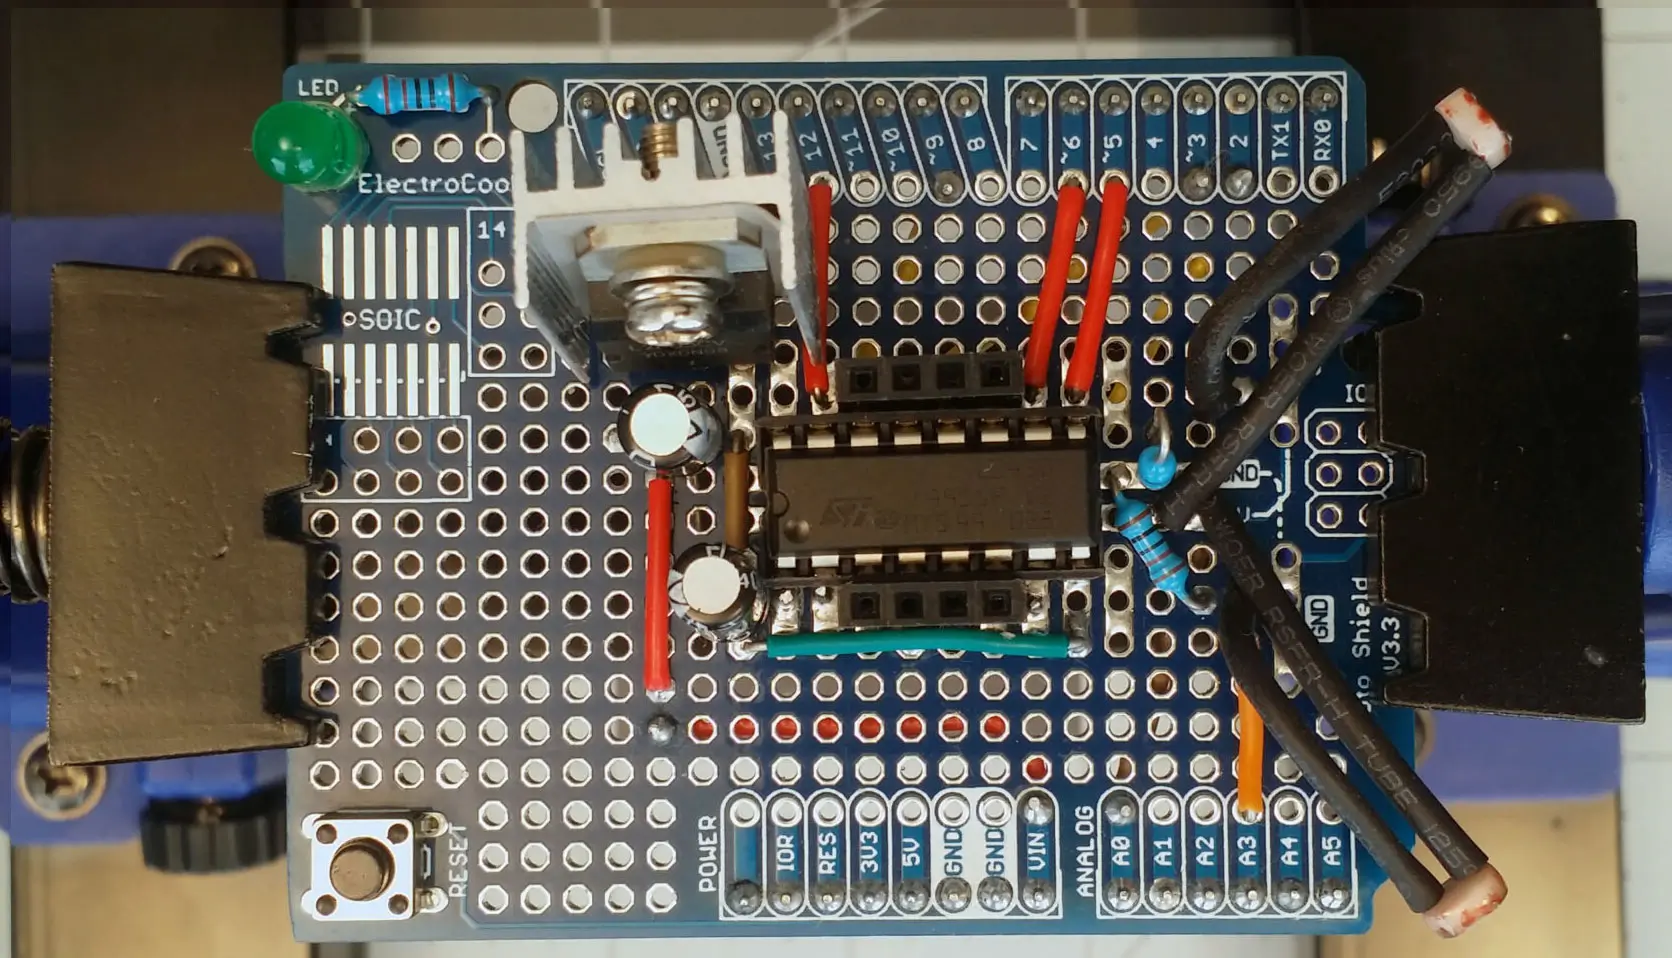
This was originally a project from Chapter 4 of Jeremy Blum’s book, “Exploring Arduino”. The last project in this chapter covers building an autonomous car that follows light. It is a great chapter that introduces transistors, voltage regulators, dc motors, h-bridges, reading schematics and other great lessons. I built the project on a breadboard and re-created the layout and schematic using Fritzing.
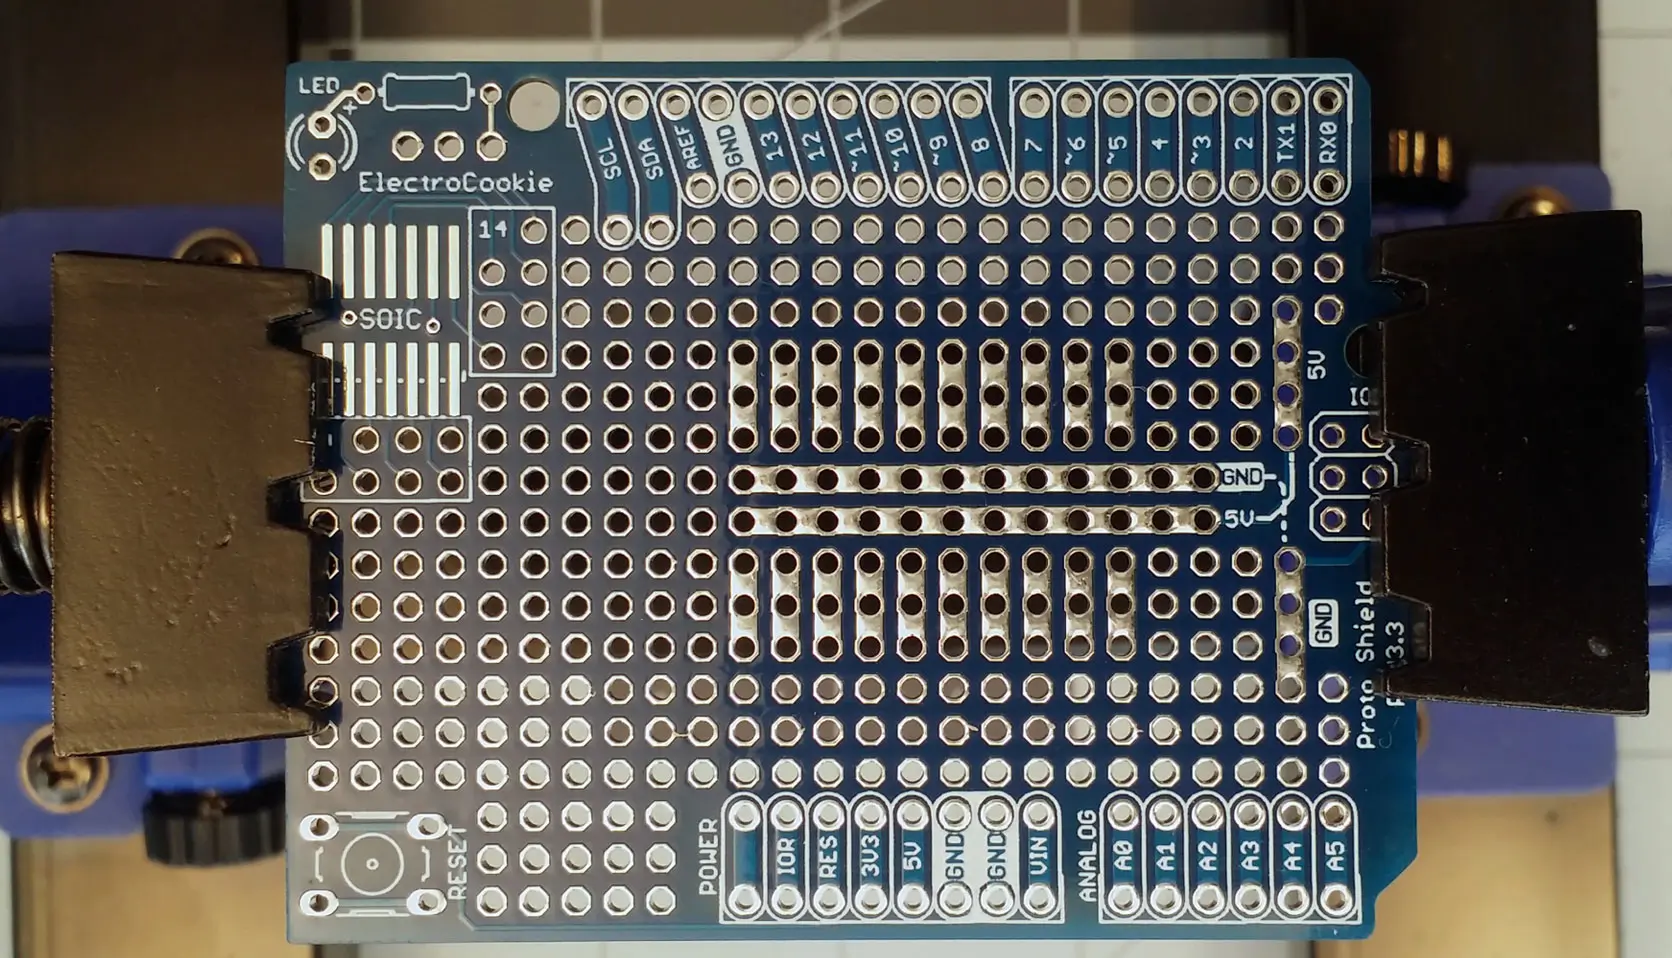
This project was very rewarding and fun. I highly recommend Blum’s book. The project was to make an actual working car using the breadboard, but Instead, I decided to take it off of the breadboard and use a protoshield. This was when I started looking for a protoshield and found the previously mentioned ElectroCookie shields.
It was my first time creating a circuit on a protoshield, so I chose one and gave it a shot. I couldn’t come up with a way to use software to plan the layout for the circuit because I wanted to use both sides, so I decided to just place the components on the shield, I visualized the layout and soldered as I thought best. I utilized the existing traces as much as possible. I 3d printed a chassis instead of purchasing another one. I put it all together and it worked. That's how I made this shield!
UPGRADE: IR REMOTE CONTROLLED CAR
Blum gives you enough
to get you started but leaves you ready for more. I think that is a great way to teach. I wanted to do more. I turned again at the smart car kit for inspiration and realized I could sort of recreate it on this shield.
I decided upgrade this project and make an IR Remote controlled car. I made a new prototype on a breadboard. The first version used this IR receiver.
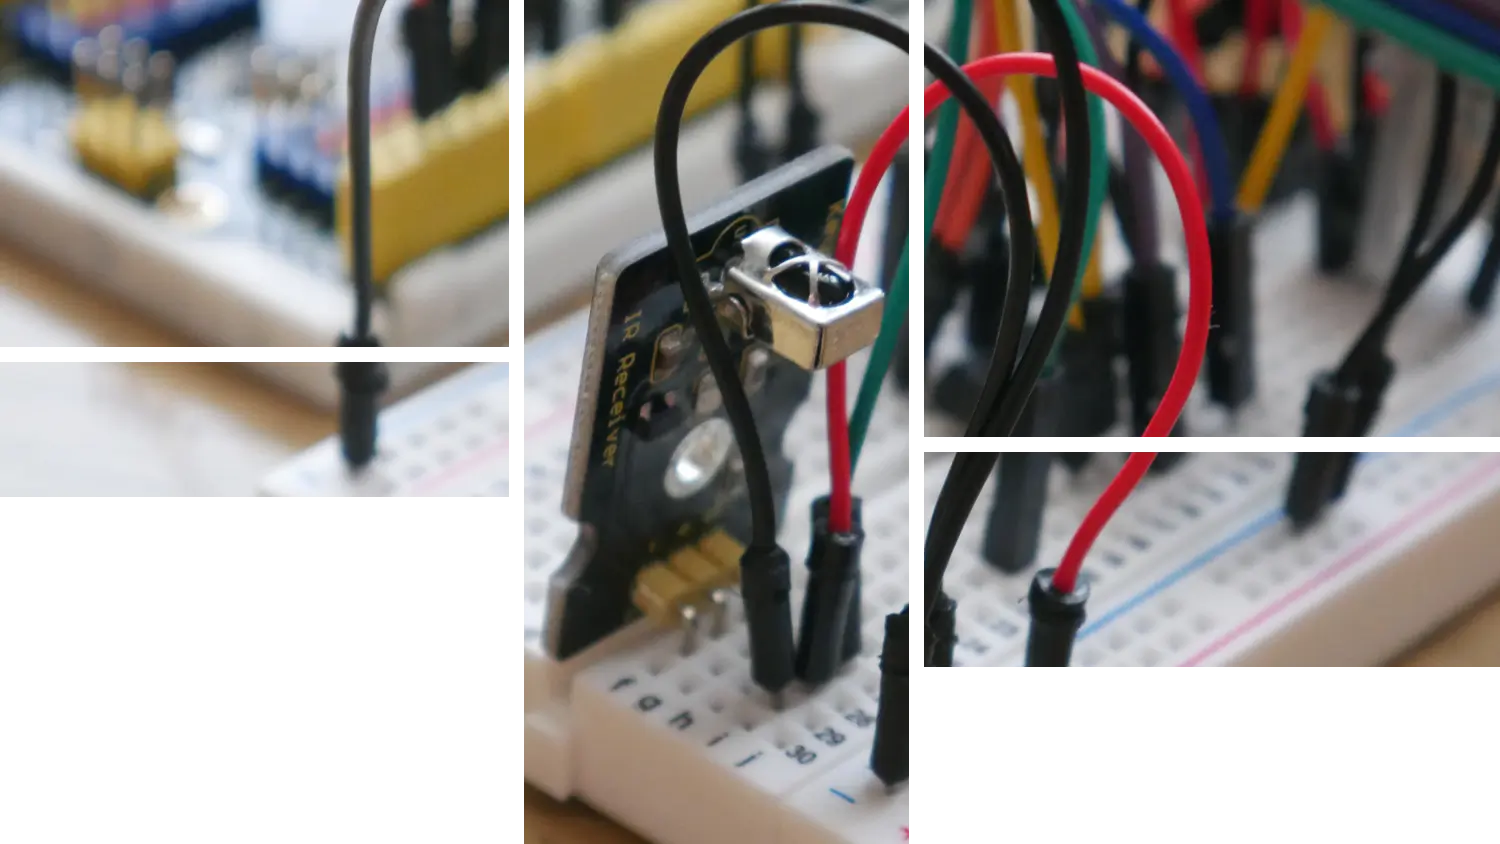
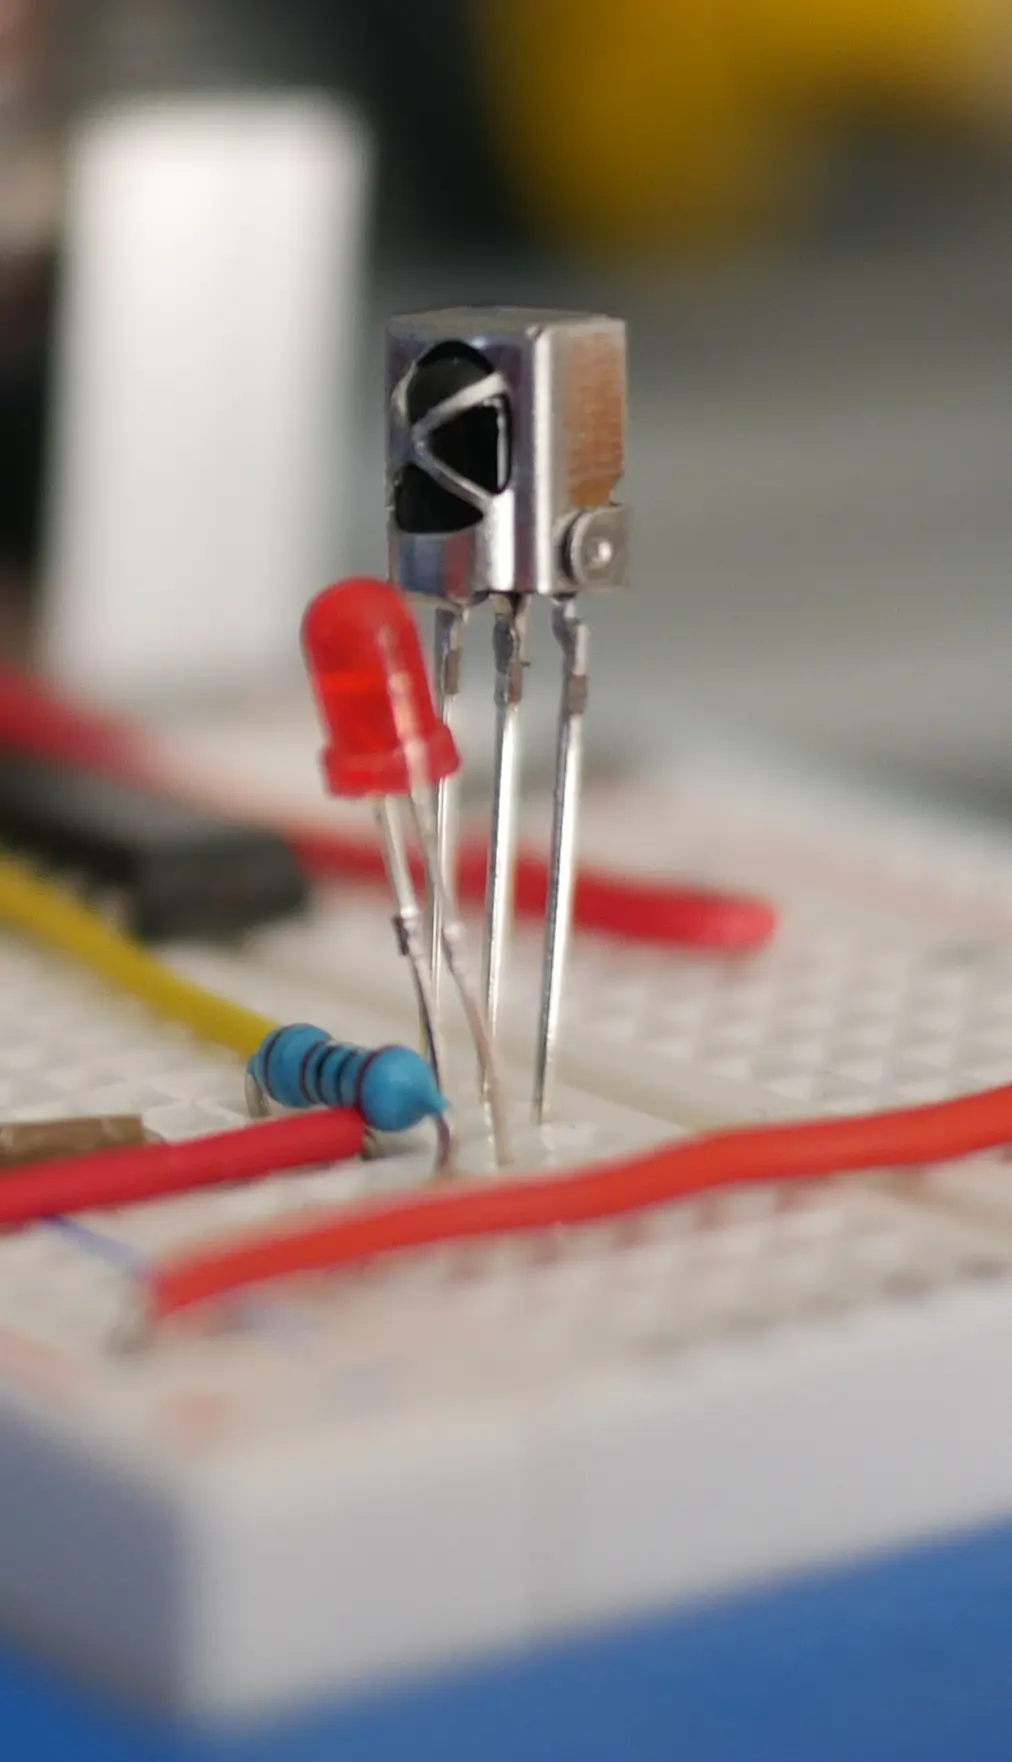
It didn't seem right to solder this beautiful Keyestudio IR receiver onto the shield. It was too nice. I decided to use a different one instead and I also added an led indicator for the IR receiver.
I thought about whether or not to start with a new shield and make an entirely different board, but it seemed like that would be a waste of components, shields, and money. I looked to the smart car kit again for inspiration. I noticed that the kit had all three versions assembled as one unit; IR remote, obstacle avoidance and ultrasonic sensor. All you have to do is upload the new sketch for whichever version you want.
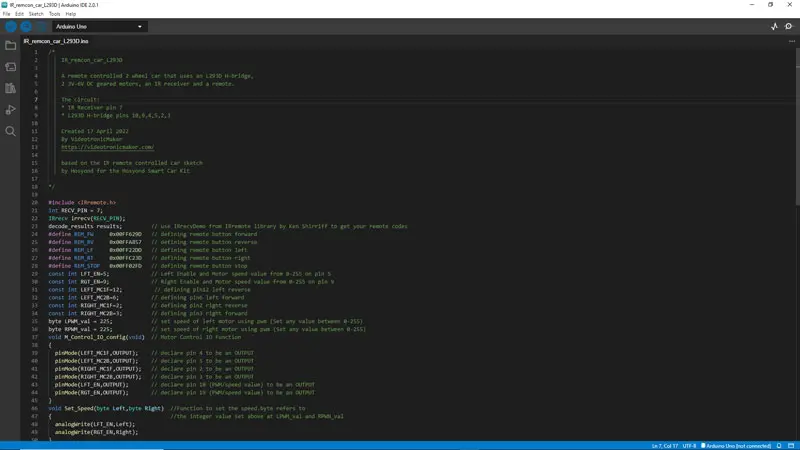
I based my code heavily on the smart car kit. I changed the H-bridge component to an L293D and renamed a few things. I pasted the code at the bottom. I decided to add the IR receiver to the existing board and not waste any components or money.
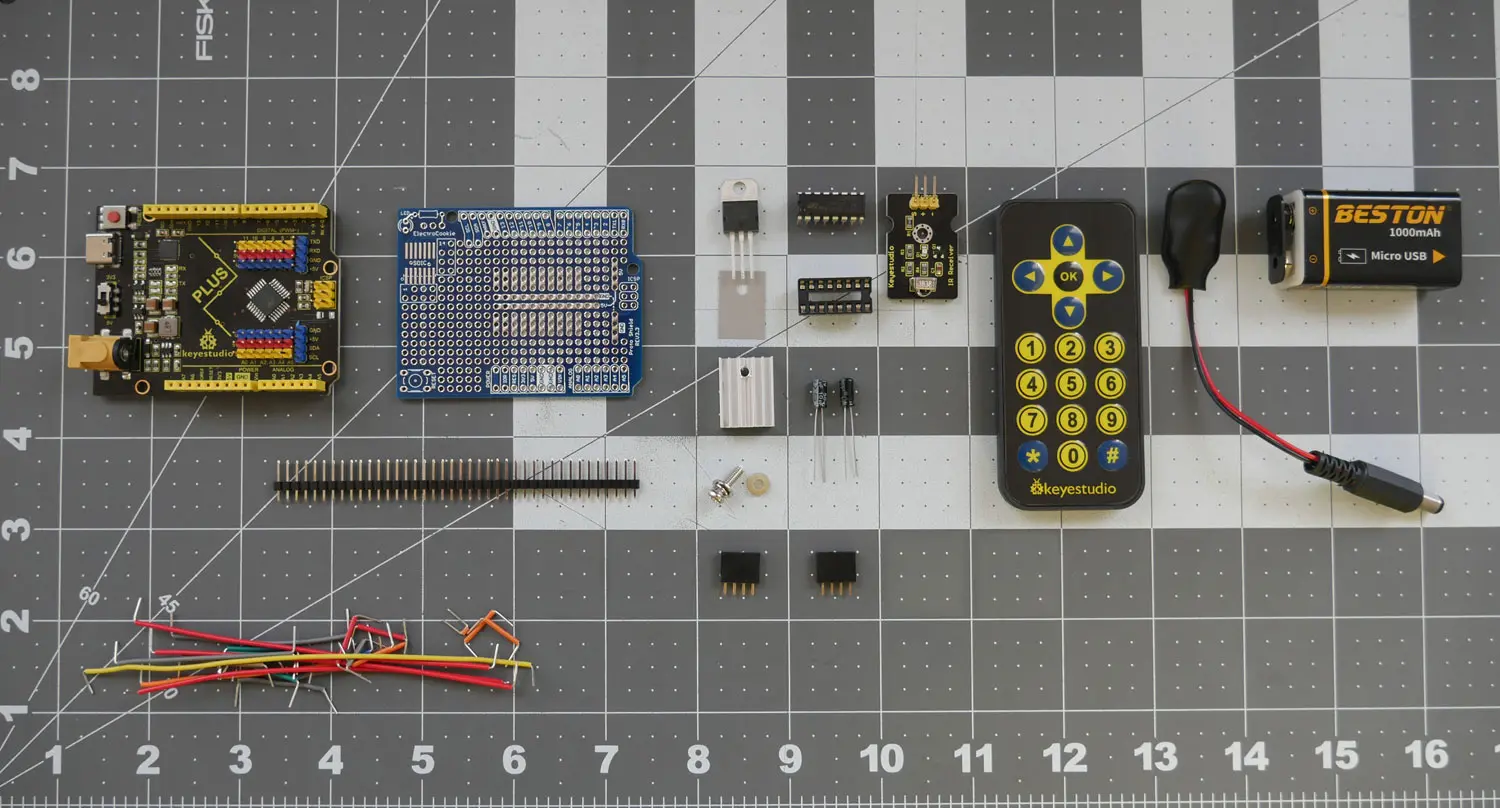
The Parts all together.
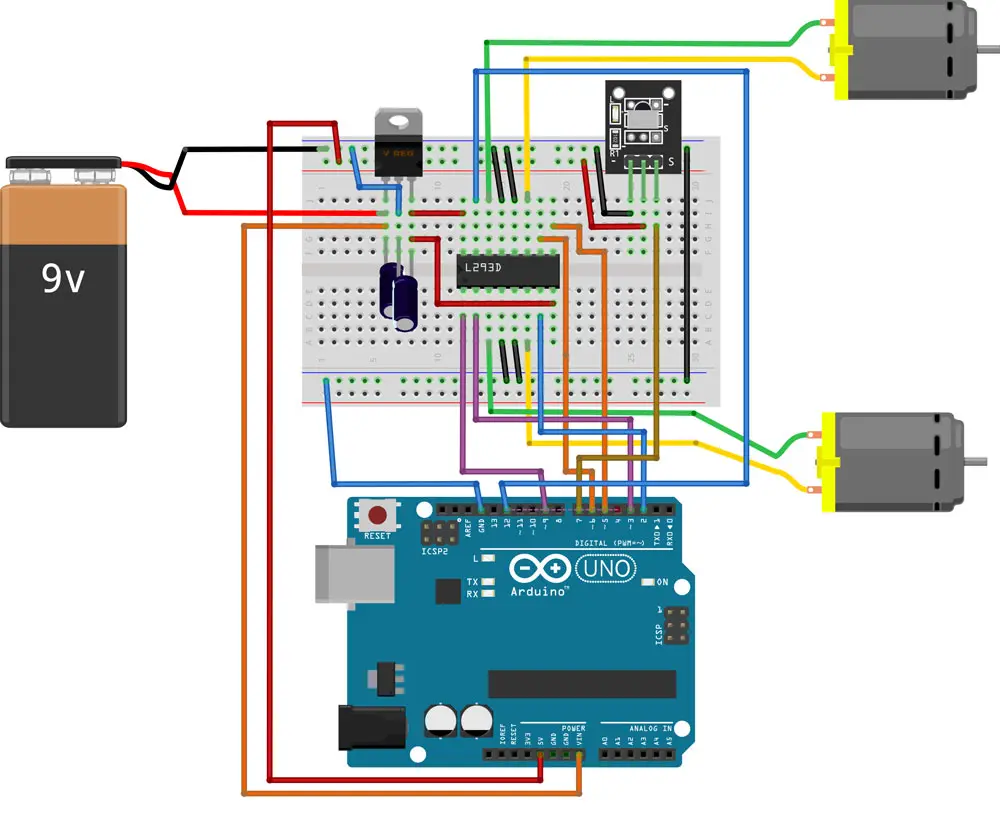
Layout in the Arduino Sketch below
Different Pin Outs
The IR receiver used in the layout image on the left is different from the IR receiver on the right. Make sure you look up the pin outs for the component you end up using. Connecting the pins incorrectly will result in the destruction of the component.
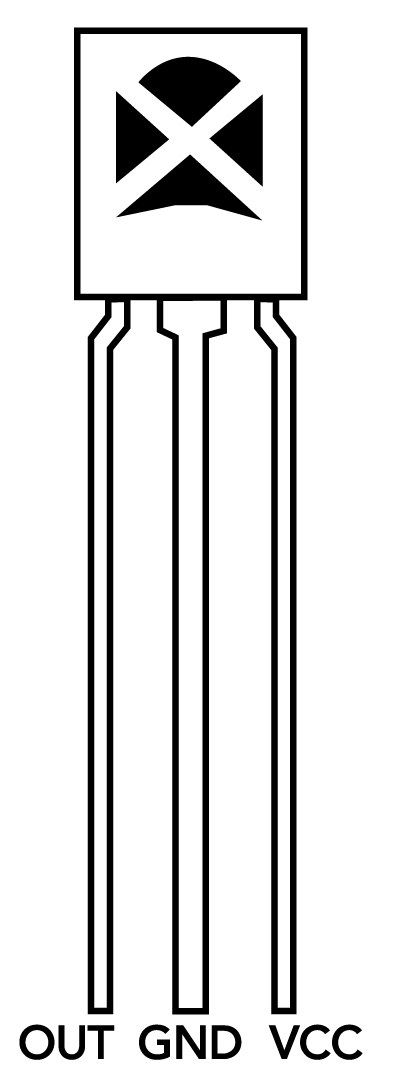
Pin Out for this IR Receiver
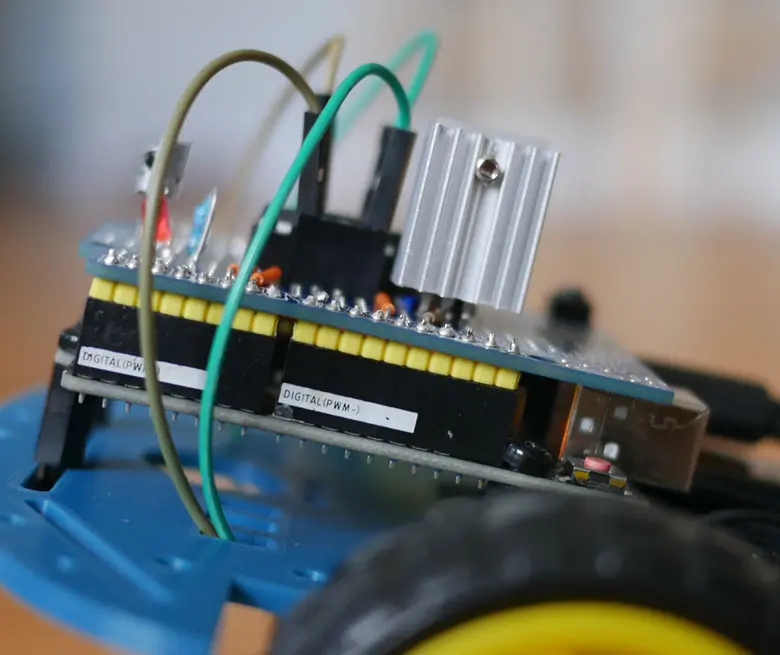
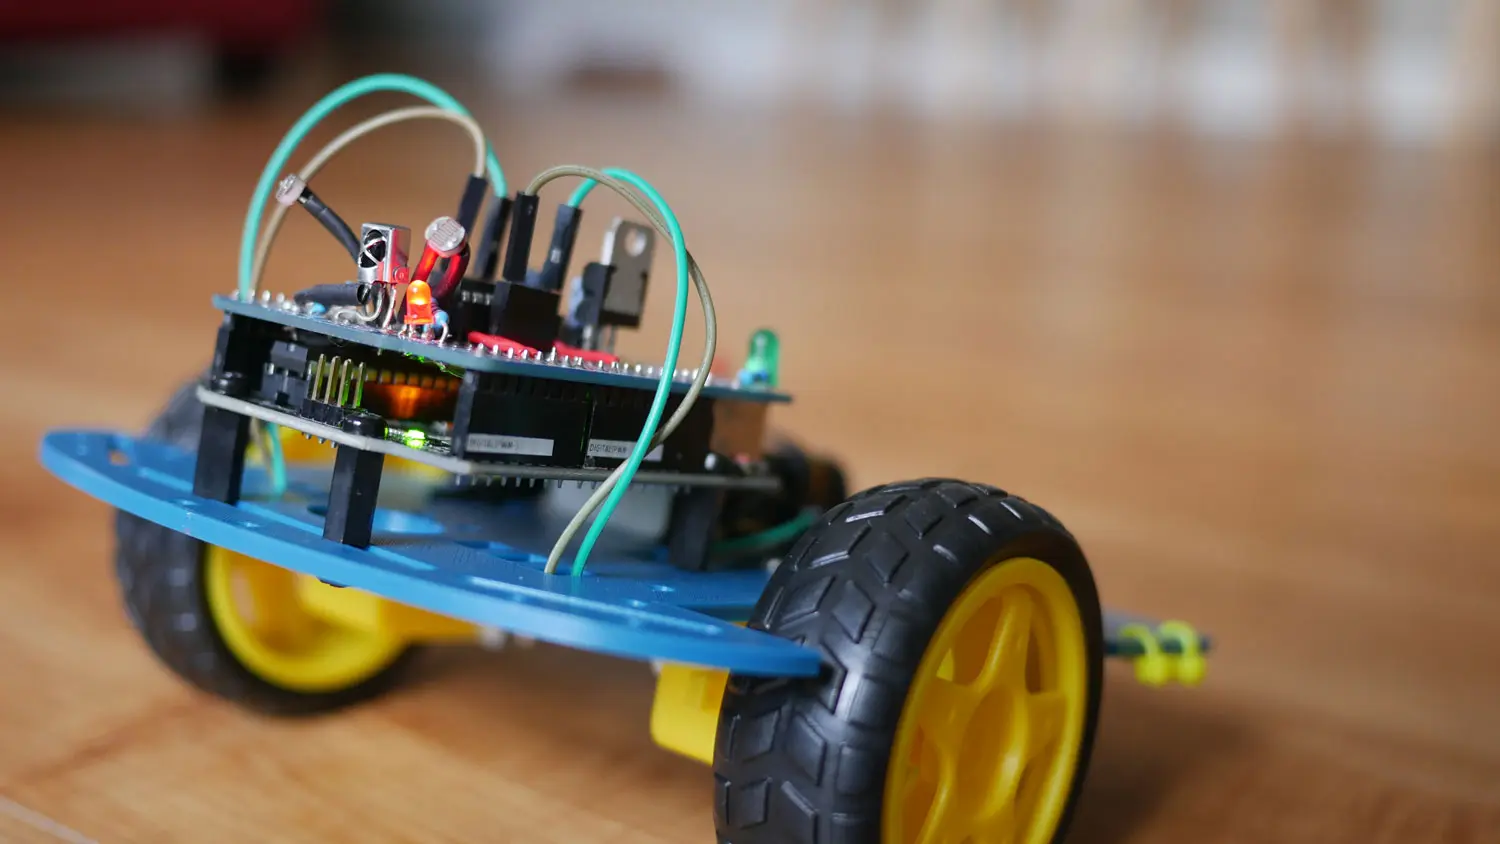
Finished Build
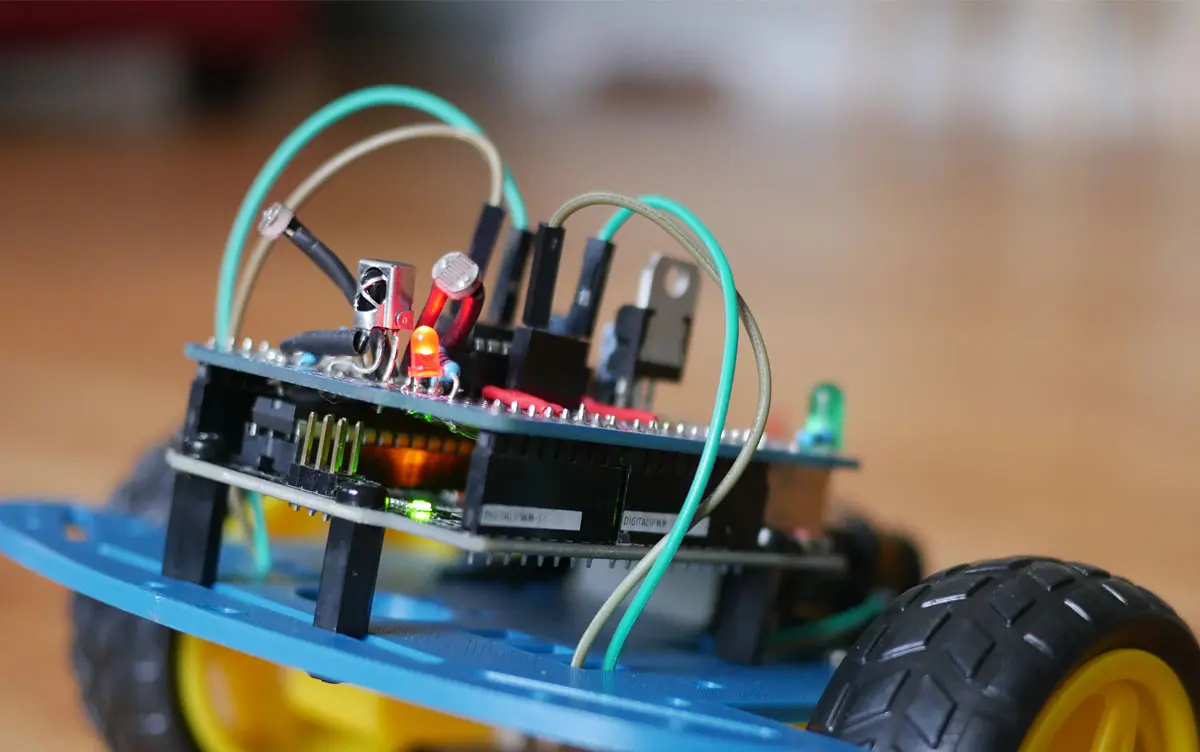
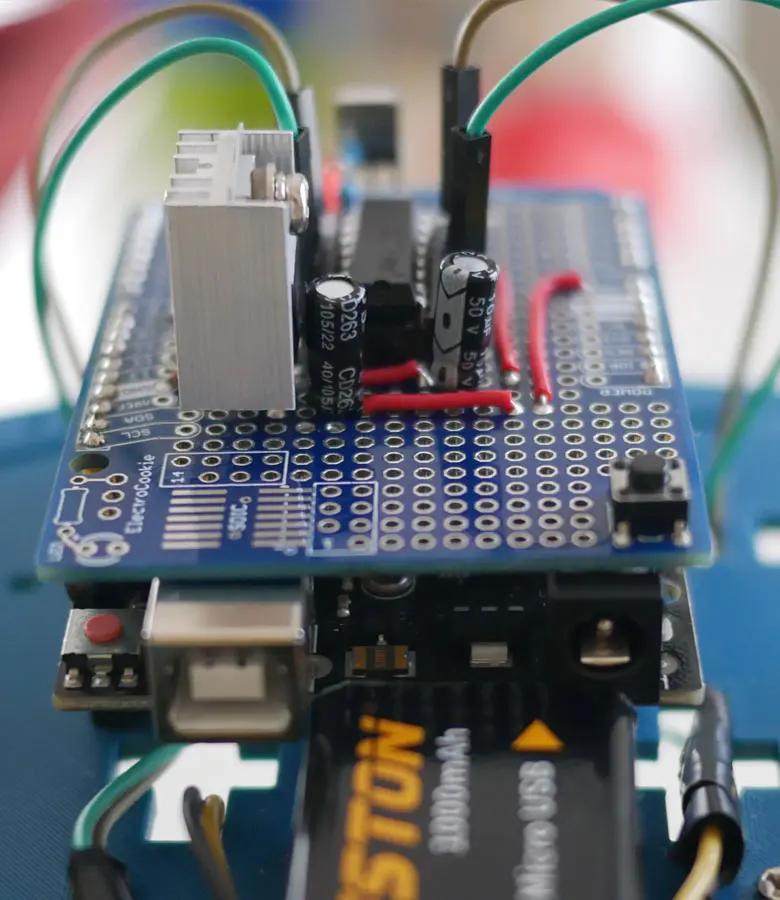
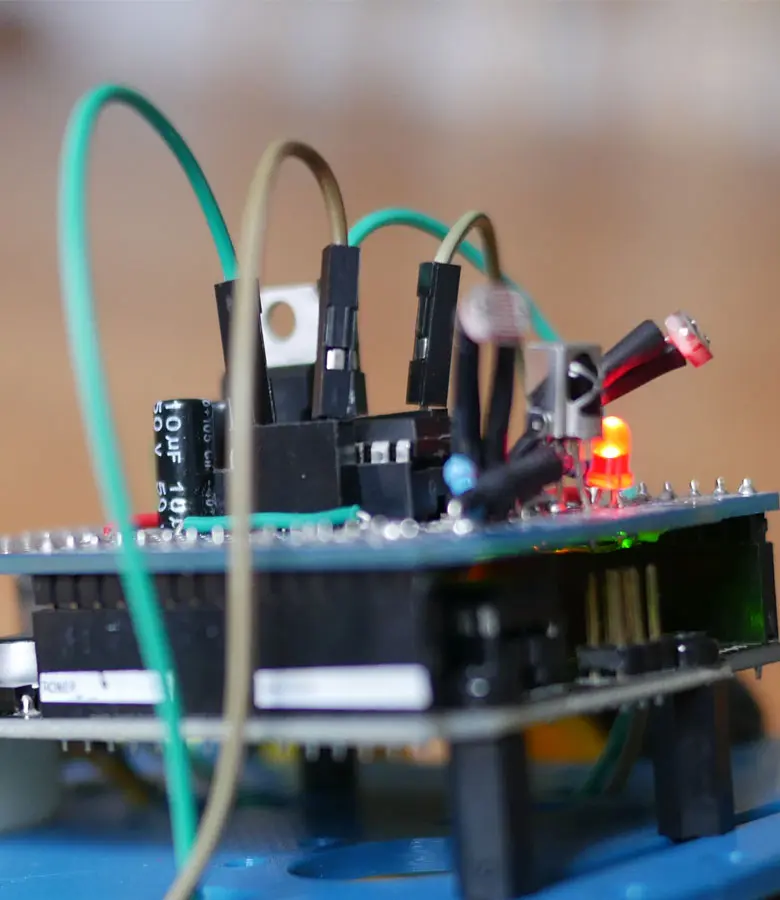
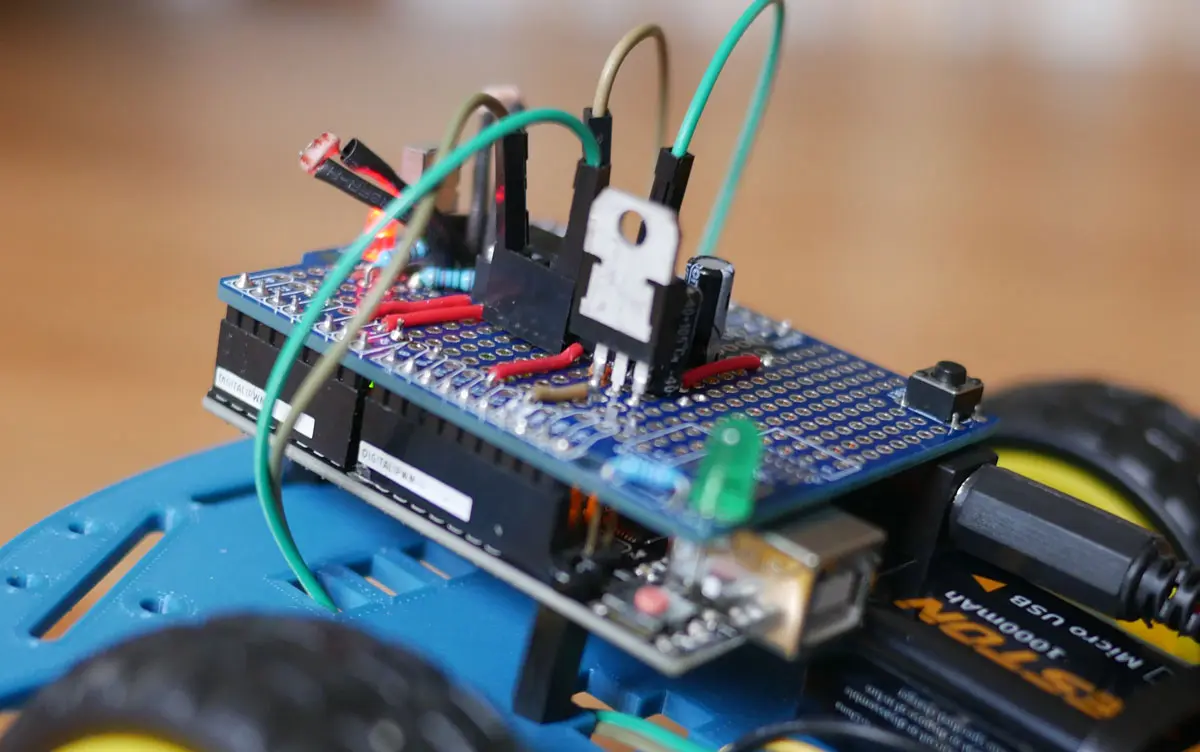
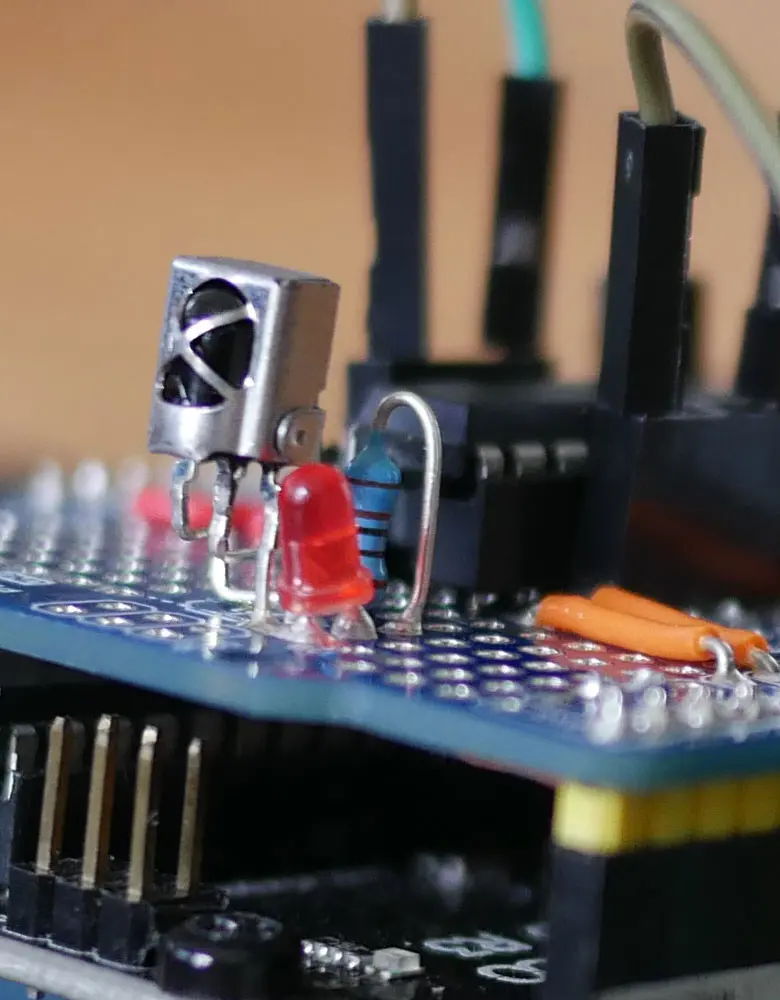
The Code
Next Steps
I knew I wouldn’t ever use the light following version of this car but I had another idea. There are 10 available pins left. I could use the photo resistors to make automatic headlights that turn on when its dark. I could also add the night rider/chasing leds feature and activate it with the remote.
Maybe I could also add a horn by using a piezo buzzer and also activate that with the remote. I won’t do all of that now but this shield has potential. I’m sure others have made the same or more complex cars but I wanted to explore uses for protoshields. This is a journey that I hope will continue on and will result in project and video updates.